Meet Our Robot
Explore custom hardware builds, sub-systems, and design evolutions created by Team #31844.
BIOBUZZ Robot
Our current season robot is actively being designed, prototyped, and tested for the BIOBUZZ 2026–2027 campaign!
Stay tuned — photos, specs, and subsystem breakdowns will be posted here as hardware testing concludes.
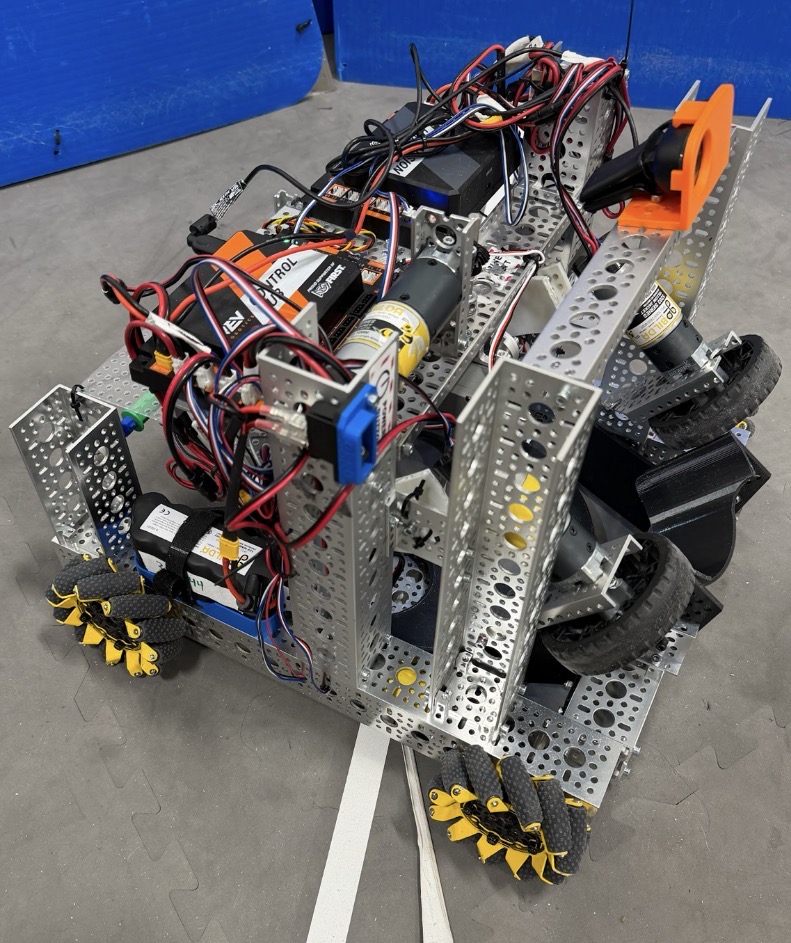
Our Robot
The robot uses a spindexer to store 3 artifacts properly and also uses 117 rpm motor to help with its accuracy. Our robot has an intake that runs at 1115 rpm to make intaking fast and effective. For our launcher we use a kicker with a torque servo to help with its accuracy in angle and to push artifacts that may be off center, this robot also use two flywheels to help with quick and laser like launching angles.
The robot performed very well at intaking and the spindexer was spot on every single time. Our kicker was accurate and made sure to push the artifacts into our launcher, but our launching was inaccurate at some moments. In the end our robot performed incredibly well.
Old Robot vs New Robot
A comparison of our early season robot and our current design.
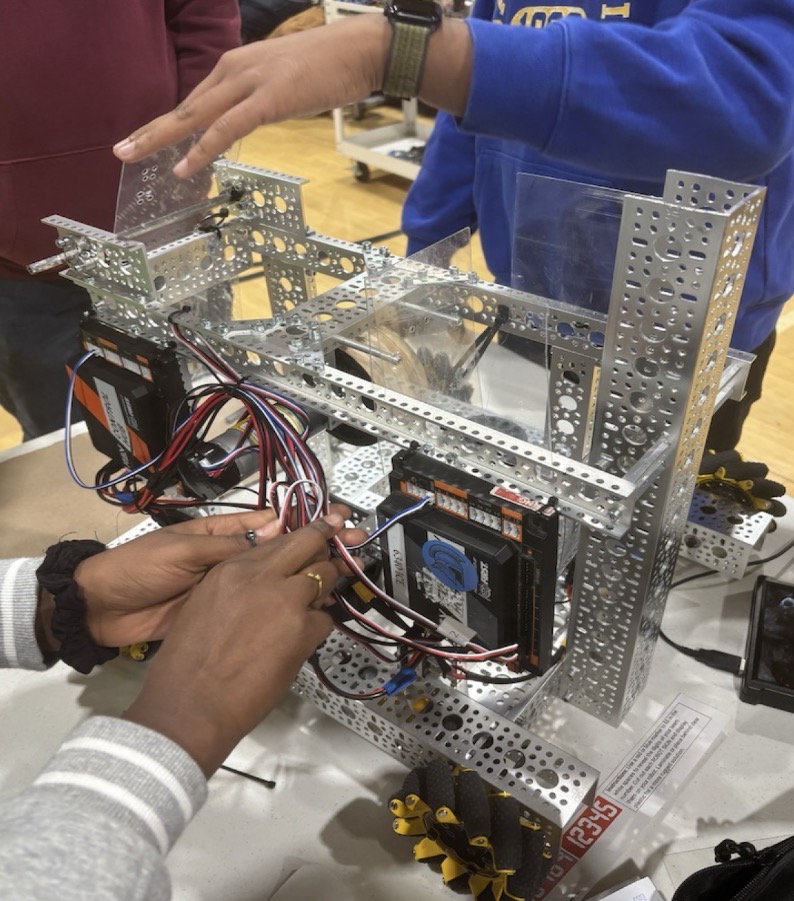
Pros
- Simple goBILDA starterbot and chassis
- Curved plastic guide improved shooting accuracy
- Strong foundation for early season testing
Cons
- Limited customization
- 3 max ball auto due to human player only
- Harder to maintain performance as competition increased
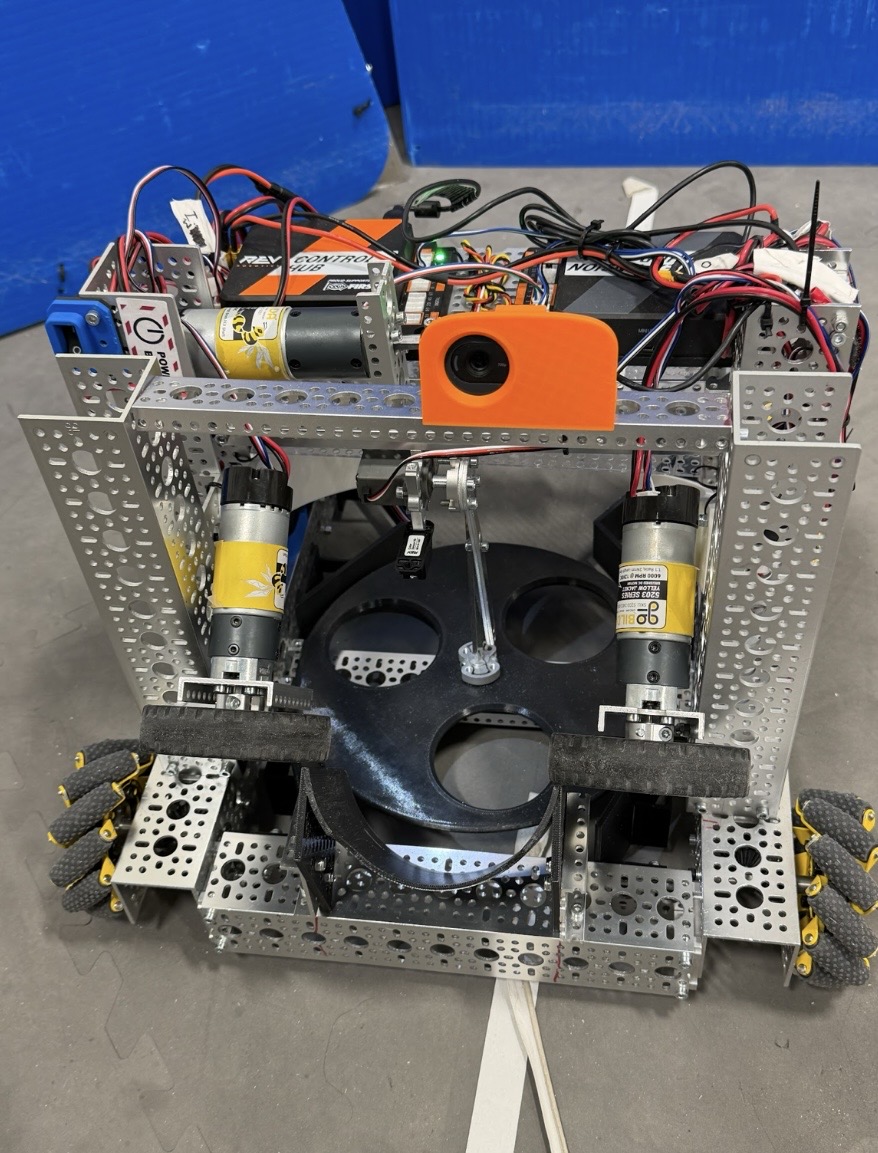
Pros
- Custom design enhanced for our game strategy
- Faster cycle times due to improved intake
- Built using lessons learned from the starterbot
Cons
- More testing needed to reach peak consistency
- Higher power requires more frequent battery changes
- Increased mechanical complexity vs starterbot
Intake System
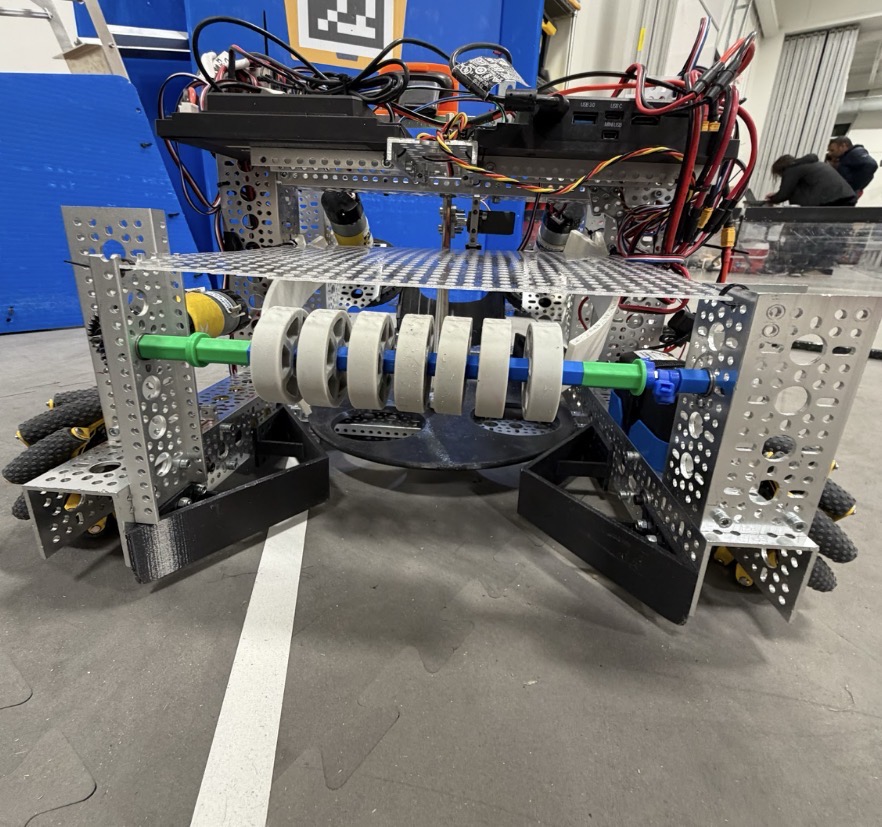
- Roller intake designed for fast and reliable ball collection
- Funnel guides balls smoothly into the robot
- Wide intake opening allows successful pickups even when slightly misaligned
- Prioritizes consistency to prevent any over capacity issues